
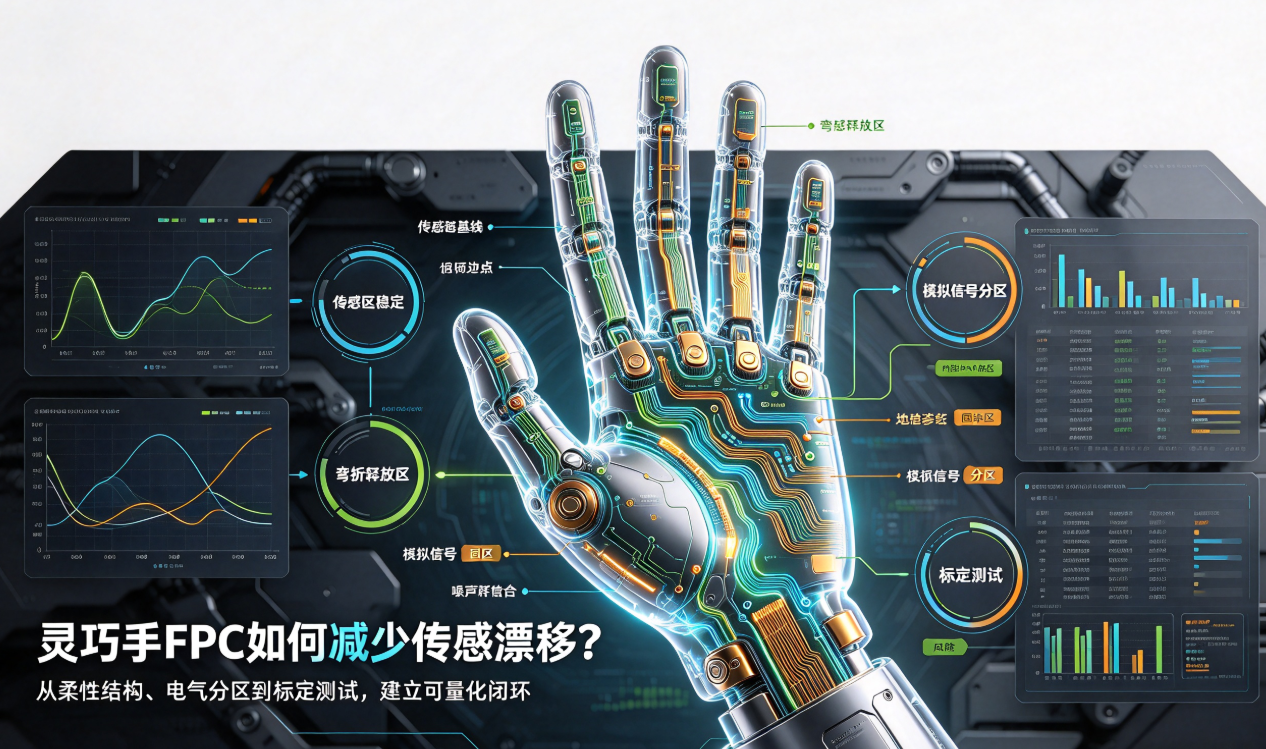
During extended operation of dexterous hands, sensor zero-point drift, tactile signal noise, and resistance variation after bending directly impair grip judgment. The root cause often lies not only in the sensors themselves but also in FPC stress relief, trace segmentation, stiffener placement, connector fixation, and calibration methodology. This article establishes a systematic troubleshooting path—from structural design to test calibration.
Why does a dexterous hand’s ‘sense of touch’ change over time?
Dexterous hands require dense integration of multiple tactile, pressure, position, and temperature sensors within extremely limited space. FPCs route these signals from fingertips, phalanges, and palms back to the control board—while simultaneously accommodating repeated finger flexion. Over time, minor resistance shifts in the FPC traces, unintended mechanical stress from stiffeners on sensors, or coupling of power drive noise into analog signals can result in zero-point drift and unstable tactile perception.
When troubleshooting such issues, simply replacing the sensor is insufficient. First verify whether the FPC’s structure, materials, and test methodology provide a stable operating environment for the sensor.
Categorize drift sources into three groups:
Drift Source | Typical Manifestation | Priority Investigation Direction Mechanical Stress | Gradual zero-point shift after bending cycles | Stiffener placement near sensors, mounting points, bend radius, and adhesive positioning Electrical Change | Abnormal resistance or noise in one channel | Trace length, copper foil geometry, connector contact integrity, and pad reliability Environmental Influence | Output offset under temperature variation | Material CTE mismatch, temperature compensation design, and high-/low-temperature test conditionsStabilize the sensing zone; ensure the bending zone has adequate ‘room to bend’.
The FPC segment adjacent to sensors must avoid repeated tensile strain. During design, locate sensor nodes, solder pads, and alignment features within relatively static zones—and confine dynamic bending to well-defined, spacious relief zones. Prior to entering the bend zone, use rounded corners, tapered trace widths, and distributed branching to mitigate stress concentration; placing vias or large pads at the bend center often creates abrupt stiffness transitions.
Analog signals require an independent ‘quiet channel’.
Tactile sensing is highly sensitive to minute voltage variations. If motor drive circuits, power switching nodes, or high-speed communication traces run parallel to analog traces over extended distances, they may inject noise into the acquisition path. On the FPC layout, segregate analog, power, and communication traces into distinct regions; optimize ground reference planes and return paths; and separate noise-sensitive pins from high-noise output pins in the connector pinout.
Testing must go beyond simple continuity checks.
For mass-produced dexterous hand FPCs, testing is recommended in at least three phases: (1) pre-assembly measurement of per-channel resistance and insulation resistance; (2) post-assembly baseline acquisition under no-load and specified load conditions; and (3) post-cycling data capture after a defined number of bends or grasp cycles. Correlating initial values, temperature, cycle count, and drift magnitude enables differentiation between intermittent contact faults and structural failure.
An engineering closed loop—from structure to calibration.
- Define sensing zones, mounting zones, and bend-relief zones using 3D structural models and motion trajectories.
- Confirm trace segmentation, shielding requirements, and connector pin assignments based on sensor type and signal characteristics.
- In the prototype phase, conduct bend-cycle testing, thermal cycling, and post-assembly baseline validation—documenting quantifiable pass/fail criteria.
- In mass production, standardize stiffener placement, lamination pressure, electrical test items, and data traceability rules.
Hongyi Precision offers comprehensive support for dexterous hand sensing FPCs—including trace layout optimization, stiffener structure design, prototype validation, and mass-production process assessment—to help customers shift sensor drift from a late-stage tuning issue to a manufacturable, testable hardware concern.