
Dexterous hand sensing FPC
As humanoid robots move into volume production, the five-finger dexterous hand has become a core interaction component, and its internal high-density tactile sensing FPC is the part that decides how the hand feels and how long it lasts. Compared with consumer electronics flex, a dexterous hand FPC must pack dense sensing nodes into a minimal space and endure far more dynamic bend cycles than usual.
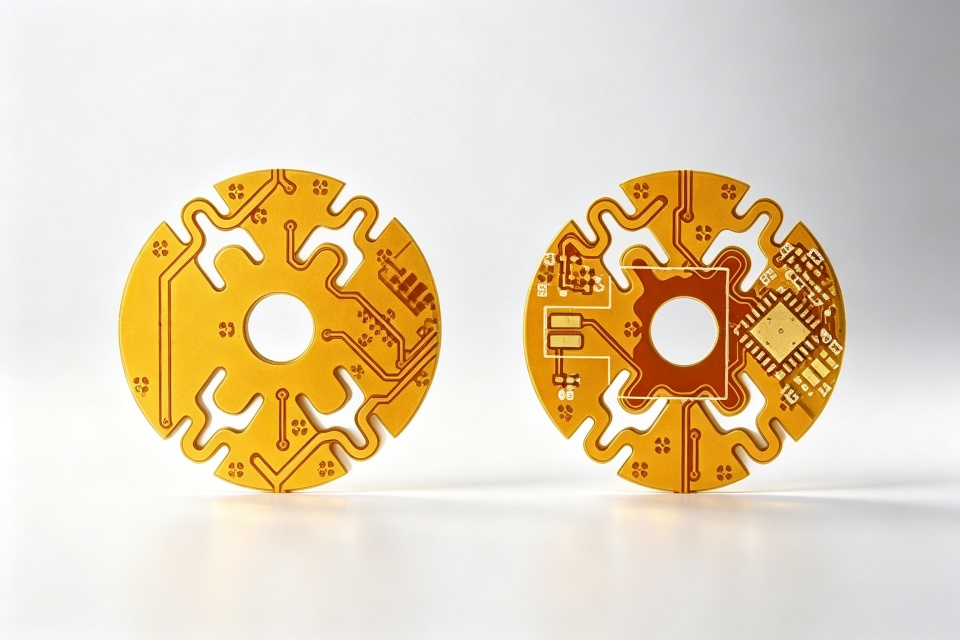
Key features
High-density sensing nodes
Densely arranged tactile pads across the finger joints raise tactile resolution.
Very high dynamic flex life
Neutral-axis design with RA copper in the knuckle bend areas extends service life.
Routing in very tight spaces
Fine line widths route multiple signals through narrow finger channels.
Consistency control
Per-piece electrical testing and resistance screening keep the feel even across all fingers.
Specifications
- Layers
- 1 – 4 layers
- Min. line width / spacing
- 50 / 50 µm
- Base material
- PI 12.5 / 25 µm
- Copper thickness
- 9 / 12 µm (RA rolled copper)
- Min. finished width
- 1.0 mm
- Surface finish
- ENIG, ENEPIG
- Electrical test
- 100 % coverage
- Bend design
- Neutral axis + dynamic bend area
Typical applications
- Five-finger tactile sensing
- Fingertip pressure sensing
- Flexible palm sensor arrays
- Robotic grasp feedback
Talk to an engineer
Share your Gerber files or specification and our engineering team will assess manufacturability, advise on process and stack-up, then move your project through sampling and volume production to automotive standards.
Quote NowRelated reading
How Do Dexterous Hand FPC Manufacturers Address High-Density Tactile Sensing and Joint-Space Constraints?
Dexterous hand FPCs face concurrent challenges: extremely confined fingertip space, dense sensor placement, repeated flexing, and serviceability during assembly. This article outlines the design logic—from signal zoning and flexible tail routing to fixation methods, connector selection, and lifetime validation.
Learn moreIndustry InsightsHow to Accept FPC Prototypes from a Prototype Manufacturer? A Closed-Loop Process Covering Electrical Functionality, Assembly, and Reliability
Accepting FPC prototypes based solely on continuity and visual inspection often fails to uncover bending, assembly, soldering, and material issues. This article outlines a practical, five-step acceptance methodology—receipt verification, static testing, assembly validation, dynamic validation, and issue closure.
Learn moreIndustry InsightsHow to Avoid Extra FPC Customization Charges: Separate One-Time and Mass-Production Costs
FPC customization cost is not determined by area and quantity alone. Engineering work, tooling, material utilization, yield, testing, SMT, packaging and engineering changes all affect total project cost. This guide helps purchasing teams compare quotations without sacrificing reliability.
Learn moreRelated products
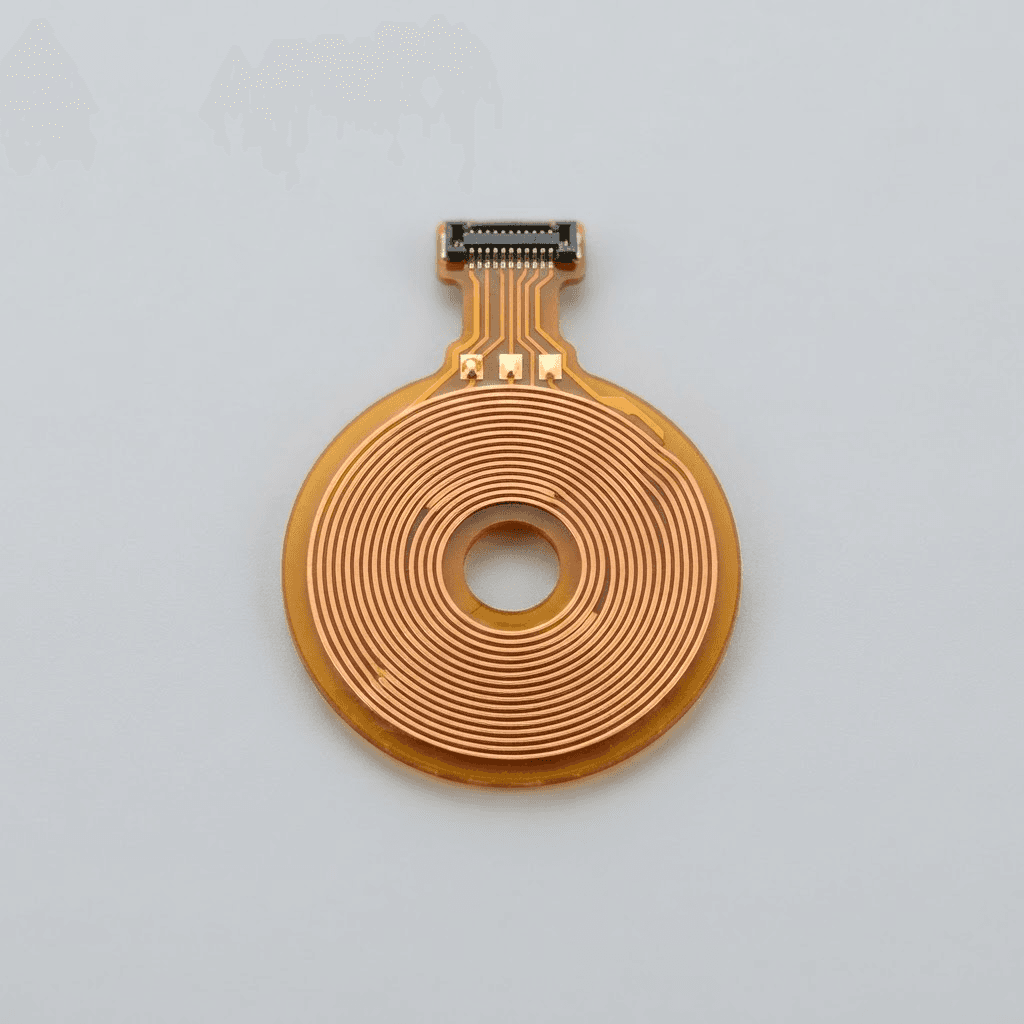
Humanoid Robot FPC
Cup Motor FPC
Precision flexible interconnects for cup motors and joint actuators.
View details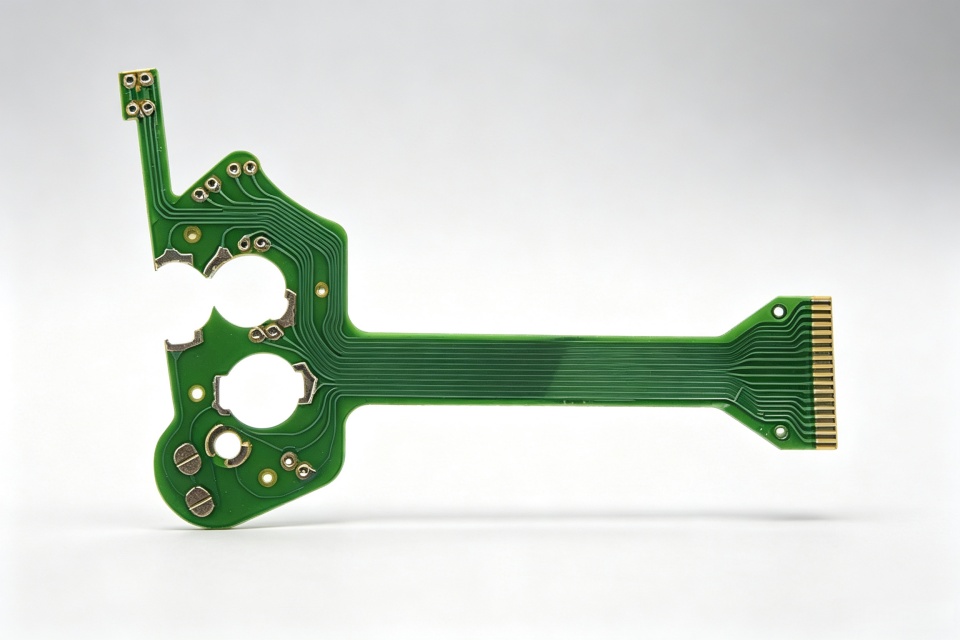
Bipedal Robot
Bipedal Robot Joint Sensor FPC
Bipedal robot joint flexible printed circuit (FPC), with zone-specific surface finishes: ENIG for functional pads and tin plating for general traces. ENIG pads enhance salt mist resistance and oxidation resistance, balancing long-term operational reliability and manufacturing cost.
View details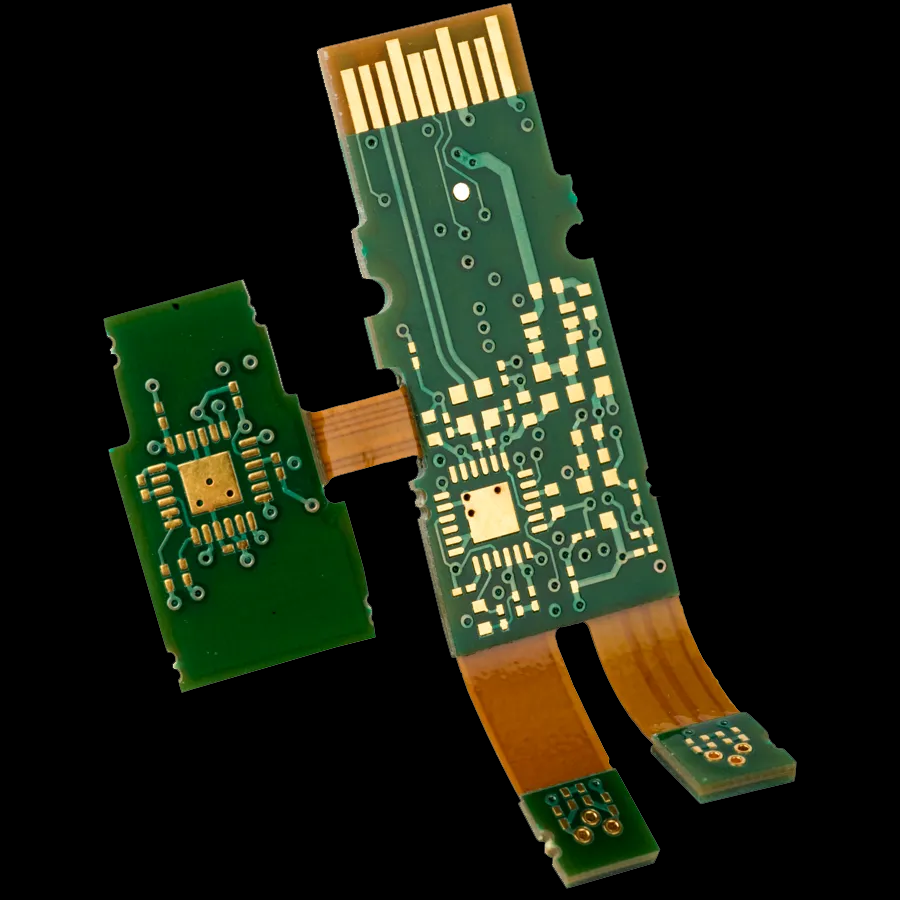
Humanoid Robot
Humanoid Robot Rigid-Flex FPC
Humanoid robot rigid-flex FPC: precisely designed mounting holes and alignment features in static areas ensure reliable assembly positioning and resistance to long-term vibration, preventing FPC misalignment and stress-induced aging.
View details