
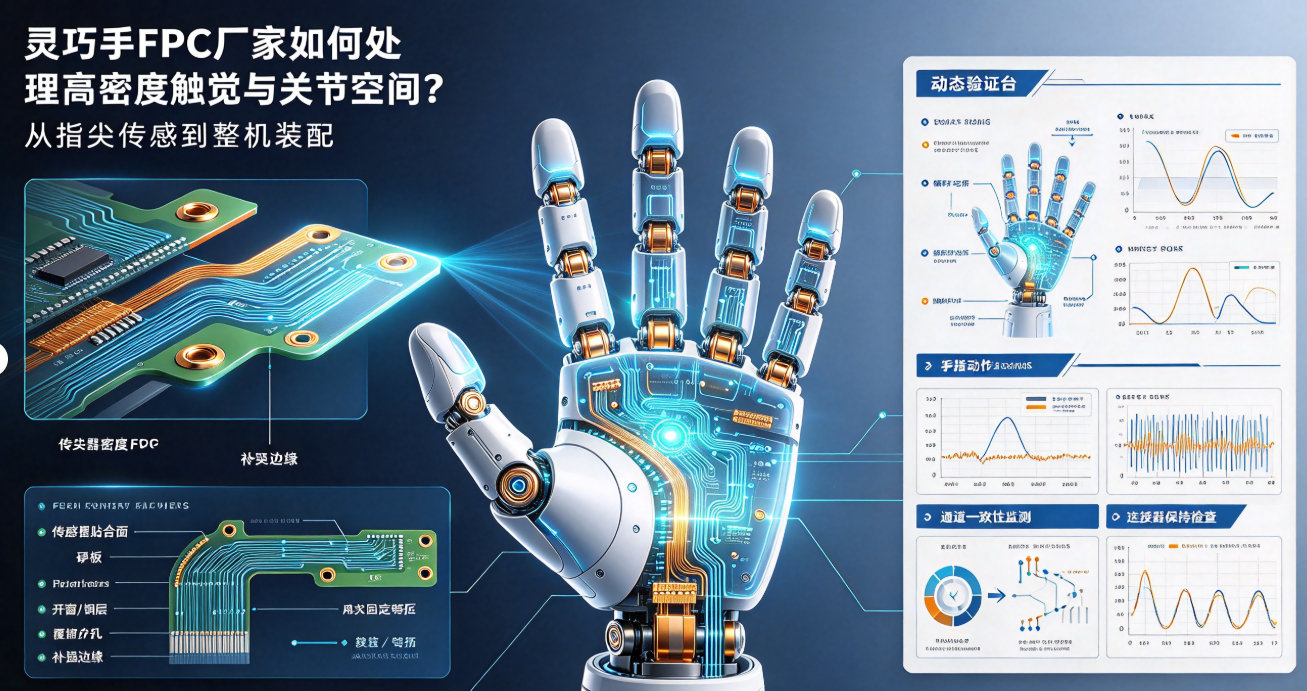
Dexterous hand FPCs face concurrent challenges: extremely confined fingertip space, dense sensor placement, repeated flexing, and serviceability during assembly. This article outlines the design logic—from signal zoning and flexible tail routing to fixation methods, connector selection, and lifetime validation.
The core challenges of dexterous hand FPCs concentrate in millimeter-scale fingertip volumes and continuously actuated finger joints. Traces must carry tactile, force, position, or temperature sensing signals while accommodating tight cavities, repeated flexing, and serviceable disassembly—treating them as scaled-down conventional FPCs often reveals integration and reliability issues during assembly or lifetime testing.
First, partition trace routing by functional finger zones.
Tactile, force, position feedback, power, and communication lines exhibit differing noise sensitivities. High-impedance sensing signals should be routed away from motor and driver traces, with clearly defined return paths across stackup, reference planes, and connector pin assignments.
Pad layouts, window openings, and sensor contact surfaces in the fingertip region are typically fixed and non-adjustable. FPC manufacturers must first confirm sensor dimensions and assembly tolerances before planning trace escape routes and tail exit locations.
High density does not equate to minimizing trace width and spacing to their physical limits.
Dexterous hand FPCs require balanced trade-offs among density, flexibility, manufacturing yield, and serviceability. Overly aggressive line-width/spacing targets increase etching, alignment, and inspection difficulty—and may heighten localized stiffness and thermal stress sensitivity in the fingertip zone.
Dynamic zones must follow actual joint motion profiles.
Finger bending involves more than simple unidirectional folding; it often includes rolling, torsion, and localized stretching. Design inputs should include joint axis, angular range, speed, fixation points, extreme postures, and adjacent components—to define static fixed zones, transition buffers, and dynamic flex zones.
Vias, pads, stiffener terminations, and coverlay openings must avoid primary dynamic stress zones. Trace orientation must align with dominant bending direction to prevent lateral kinking during flexing.
Fixation and stiffening strategies must preserve sensor accuracy.
Too few fixation points cause flapping and abrasion; too many restrict natural motion. In fingertip sensing zones, stiffeners, adhesive layers, or screw pressure must not alter sensor loading conditions. Stiffeners should be applied selectively—at connectors and critical assembly alignment locations.
Connectors and tails represent high-frequency failure points.
Connector thickness, latching mechanism, mating direction, and bend initiation point must be fully coordinated with the finger housing geometry. Forced sharp bends at the tail may cause trace fracture or micro-motion at the connector interface. Prototypes must be inspected for service clearance and maintenance accessibility after full assembly.
Dexterous hand FPC validation must cover both signal integrity and mechanical motion.
Verify zero-point stability, noise floor, crosstalk, and channel-to-channel consistency across all sensing channels;
Execute bending, torsion, and cyclic motion along real finger trajectories;
Monitor critical channels under active motor operation and maximum load conditions;
Inspect connector retention, stiffener edge integrity, solder joints, and cavity interference;
Document assembly state and pre-/post-failure signal behavior.
Hongyi Precision supports dexterous hand projects from 3D structural modeling, sensor layout, and motion trajectory analysis—through FPC and FPCA density planning, flex design, prototyping, and dynamic validation.