
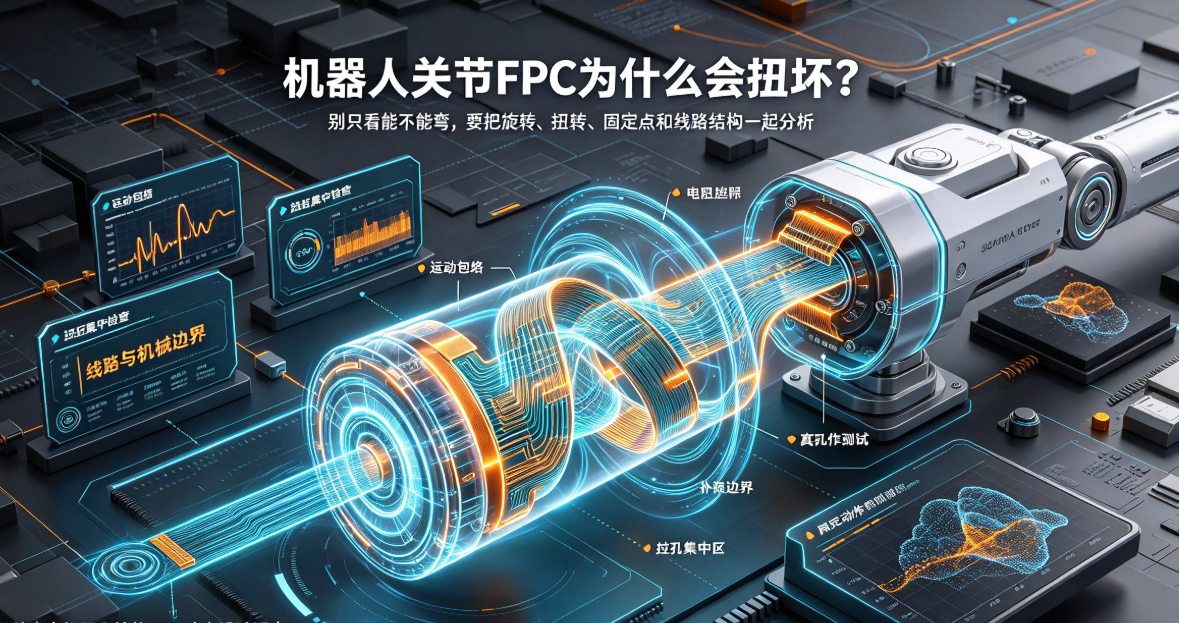
Robot joint FPCs endure not only bending but also twisting, oscillation, and axial stretching. This article outlines the design methodology—from motion envelope and twist center to fixation points, routing, connectors, and dynamic testing.
First, the conclusion:The service life of robot joint FPCs cannot be represented solely by 'bend cycles.' Joint motion may simultaneously involve rotation, oscillation, torsion, and axial stretching; the actual stress on the FPC depends on the rotation center, motion envelope, fixation points, connectors, and trace orientation.
If an FPC manufacturer designs solely along a planar curve, localized kinking, friction, connector eccentric loading, and fatigue at bend boundaries often occur after installation. Dynamic design must first reconstruct the joint motion, then define the FPC’s free and fixed segments.
I. Establish the joint motion envelope first.
Customers must provide the rotational axis, angular range, speed, acceleration/deceleration profile, cycle count, extreme poses, adjacent components, fixation points, and cable exit location. The FPC’s minimum bend radius must account not only for static assembly but also for instantaneous posture and torsional angle during motion.
Only after clearly defining the motion envelope can static fixation zones, transition buffer zones, and dynamic working zones be properly delineated. Without defined motion boundaries, any life claim lacks comparable conditions.
II. Trace orientation must align with rotation and torsion.
Trace routing, copper distribution, and via placement influence how the flexible circuit bends and twists. Concentrated vias, abrupt copper width changes, sharp trace corners, and stiffener terminations may create local rigidity or stress concentration.
The dynamic zone should maintain structural continuity wherever possible—avoid placing pads, connectors, or rigid stiffeners at primary torsion locations. When branching is required, verify that branches do not rub against each other or become pinched by the housing during joint motion.
III. More fixation points do not necessarily mean greater stability.
Too few fixation points may cause the FPC to flap, abrade, or pull on the connector; too many restrict natural movement of the free segment, concentrating stress at fixation edges. Fixation location must be jointly determined by motion center, bend direction, and assembly clearance.
Fixation structures must also be inspected for potential damage to the coverlay from clips, screws, tape, or housing edges. Thermal expansion differentials may further alter load distribution in the fixed segment after temperature cycling.
IV. Connector ends require control of eccentric loading and micro-motion.
The connector end is typically the stiffest region of the FPC—and a common concentration point for dynamic risk. End thickness, stiffener flatness, insertion depth, locking mechanism, and exit direction all affect contact stability.
If the FPC persistently pulls the connector laterally during motion, contact resistance variation and intermittent open circuits may result. During dynamic validation, monitor connector retention, solder joints, stiffener edges, and critical signal integrity concurrently.
V. Life testing must simulate real-world motion.
Test protocols must explicitly define rotation angle, torsion angle, stroke, speed, frequency, cycle count, temperature, power-on state, fixture configuration, and failure criteria. For critical circuits, recommend online monitoring of continuity, resistance, or functional signals—not just pre- and post-test static electrical measurements.
Test samples must document drawing revision, material lot, and assembly status. Different fixation methods, connectors, or housings may significantly alter test outcomes; bare-board test data cannot be directly equated to full-system life.
How should robot FPC manufacturers demonstrate dynamic capability?
Ability to establish motion envelopes and dynamic zone boundaries from 3D mechanical structures;
Ability to differentiate between bending, twisting, oscillating, and stretching operational modes;
Ability to perform integrated design of traces, stiffeners, fixation points, and connectors;
Ability to conduct online dynamic validation using tooling closely matching actual assembly conditions;
Ability to trace materials, drawings, test conditions, and failed samples.
Hongyi Precision provides 3D structural evaluation, dynamic bending and torsion design, engineering prototyping, reliability validation, and volume production support for FPC and FPCA used in humanoid robot joints, dexterous hands, vision modules, and motor modules. Specific life targets are defined per customer’s full-system operating conditions and mutually approved test plans.
Summary:The dynamic service life of robot joint FPCs depends on whether the motion envelope, trace orientation, fixation points, connectors, and test fixtures collectively follow a consistent design logic. Only when torsional loading is accurately replicated does life data hold engineering relevance.