
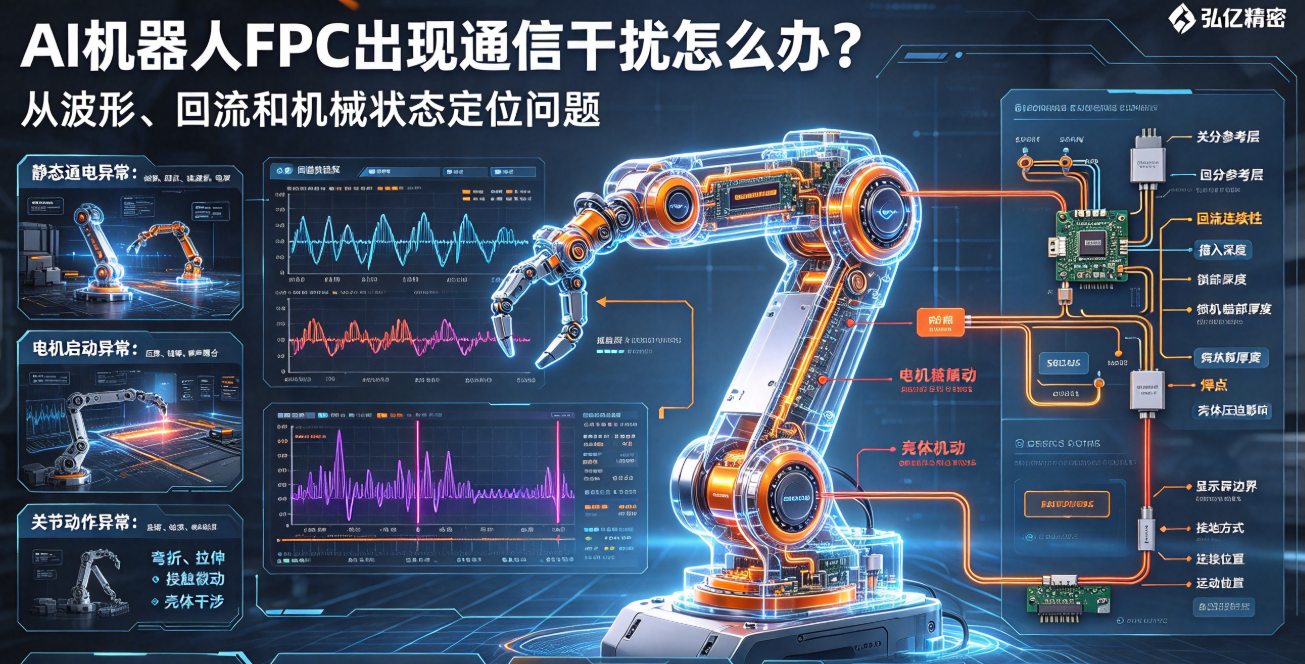
Communication anomalies in AI robot FPCs may occur only during motor startup, joint movement, or high-load inference. This article adopts a field-debugging approach—layered diagnosis from fault reproduction, waveform comparison, reference ground, connector integrity, and motion state.
Communication anomalies in AI robot FPCs do not always appear during static lab testing. Packet loss, retransmission, image errors, and momentary disconnection may occur during motor startup, driver switching, high-frame-rate camera operation, or joint articulation. When diagnosing such issues, avoid blindly replacing the FPC or adding shielding alone; instead, simultaneously log electrical and mechanical states.
Categorize faults into three scenarios:
Abnormal behavior upon static power-up points to wiring, impedance, connector, or power supply issues; anomalies at motor startup suggest power rail droop, ground bounce, or noise coupling; anomalies during joint motion require additional inspection of bending, stretching, micro-motion at contacts, and housing interference.
Capture synchronized waveforms for evidence:
During debugging, simultaneously acquire communication waveforms, power supply voltage, ground potential, fault timestamps, and joint angles. Relying solely on communication error counters—without corresponding power and motion data—makes it difficult to determine whether the root cause lies in signal integrity or mechanical intermittent disconnection.
Inspect return paths and connectors:
Differential pairs require a stable reference plane; vias, stubs, connectors, and shield grounding points must not interrupt the return current path. Connector insertion depth, latching integrity, end thickness, and solder joints must be observed under motion. An FPC that passes flat-state tests may exhibit impedance shifts or contact degradation after assembly due to housing compression.
Integrate shielding with mechanical design:
Adding a shield layer increases thickness and stiffness, potentially reducing flex-life in dynamic zones. Shield boundaries, grounding methods, and attachment locations must align with motion trajectories. If interference occurs only at a specific joint angle, prioritize inspection of shield integrity, reference ground continuity, and FPC orientation at that position.
Validate corrective measures:
Compare communication bit error rate (BER) and waveforms between static and full-load conditions;
Monitor power supply and ground during motor startup, braking, and acceleration/deceleration;
Execute real-world motion trajectories and log fault-inducing joint angles;
Conduct comparative testing with alternate connectors, FPCs, or shielding configurations;
Re-test communication functionality after thermal cycling, vibration exposure, and long-term operational cycling.
Hongyi Precision supports high-speed routing, shielding, connector integration, and dynamic failure analysis for AI robot FPCs. A professional AI robot FPC solution must enable reproducible faults, interpretable waveforms, and verifiable modifications—not iterative trial-and-error.