
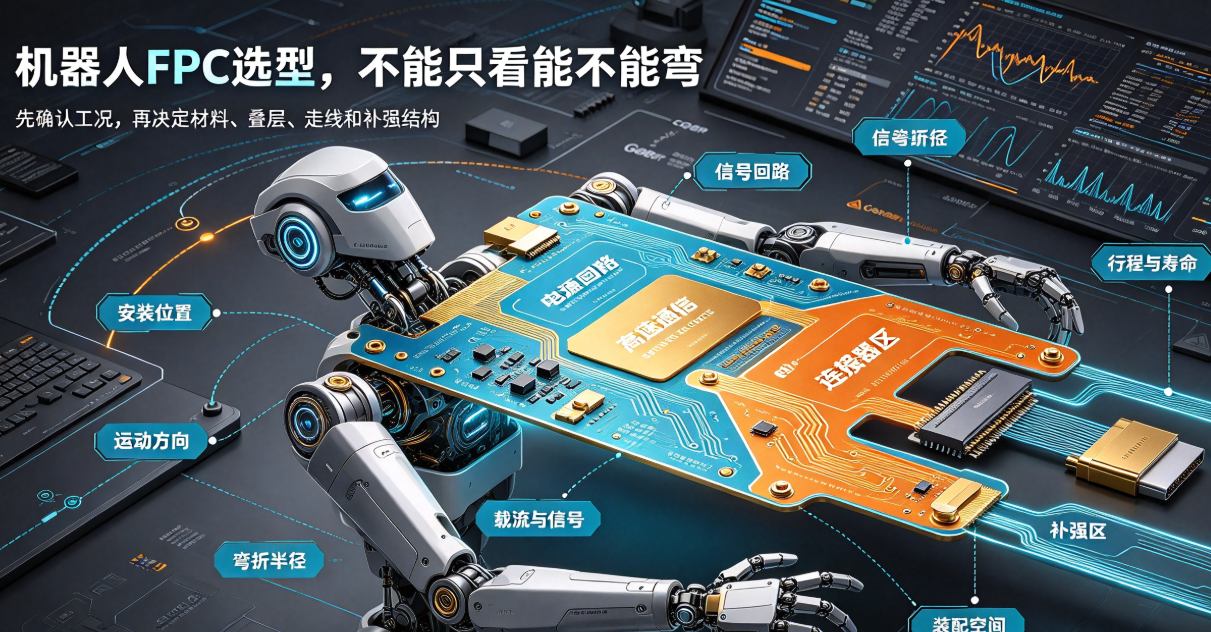
Robot FPCs are not ordinary flexible interconnect cables. This article outlines five critical evaluation criteria—motion path, spatial constraints, signal integrity, material selection, connectors, and validation protocols—essential for selecting FPCs in robotic applications.
Direct answer:Selecting FPCs for robots cannot rely solely on bendability or substrate thickness. First confirm the installation location, motion direction, minimum bend radius, stroke length, cycle count, signal type and current rating, connector interface, operating temperature, and available assembly space—then determine material, stack-up, trace layout, and stiffener design.
Motion profiles differ across robot joints, dexterous hands, vision modules, and motor internals. Applying a single FPC solution universally risks bending fatigue, connector misloading, signal interference, or mechanical interference during assembly.
1. Identify the target module for FPC installation.
Joint-mounted FPCs typically endure rotation, oscillation, or torsion—key considerations include motion trajectory, anchoring points, neutral axis positioning, and dynamic service life. Dexterous hand FPCs face tighter spatial constraints, higher branch counts, and must interface with tactile sensors, buttons, or micro-actuators. Vision and control modules prioritize high-speed signal integrity, impedance control, shielding, and connector performance.
Therefore, when requesting quotations, avoid generic terms like 'robot FPC.' Instead specify the exact module (e.g., elbow joint, thumb actuator, stereo camera), motion profile (e.g., ±90° rotation at 2 Hz), and assembly state (e.g., pre-bent, constrained by housing). Clearer application boundaries yield more comparable design proposals and pricing.
2. Evaluate dynamic zones holistically—bend radius, stroke, and fixation method together.
Dynamic bend-cycle life is not an isolated numerical specification. Robot FPCs require explicit definition of minimum bend radius, stroke length, motion direction, frequency, daily cycle count, target service life, and ambient temperature. Too few anchoring points cause flapping and tensile stress; too many concentrate stress at bend boundaries.
Suppliers should define dynamic, static, and connector zones based on 3D mechanical structure—then optimize trace routing, stiffener placement, and connector support accordingly—not finalize 2D layouts first and retrofit later.
3. Signal integrity, current-carrying capacity, and shielding must be co-optimized.
Robot FPCs may simultaneously route power, encoder signals, tactile sensor data, and high-speed communications. Trace width/spacing, copper thickness, stack-up configuration, reference planes, return paths, and shielding structures interact critically. Adding shielding improves EMI performance but may increase thickness and reduce flexibility.
Near motors, drivers, and power stages, verify thermal rise, crosstalk, and connector pin assignments. For impedance-controlled or high-speed signal layers, confirm achievable manufacturing tolerances and validation methodology during DFM review.
4. Validation must occur under near-realistic assembly conditions.
Passing continuity tests in flat-lay condition does not guarantee reliability after installation into joints or fingers. Validation should use actual housings, connectors, fasteners, and motion trajectories—monitoring key circuit continuity, resistance drift, or functional signal integrity throughout motion cycles.
Samples must document drawing revision, material lot number, bend test parameters (radius, angle, cycles), test count, and failure criteria. This enables root-cause analysis during design iteration or mass production—distinguishing whether changes stem from design, material, or process.
5. What evidence matters when evaluating robot FPC suppliers?
Beyond equipment photos and sample images, assess whether the supplier can deliver 3D DFM analysis, material and stack-up recommendations, connector and stiffener review, dynamic validation capability, failure analysis, and full batch traceability. Suppliers who translate motion requirements into design constraints and test plans add far more value than those merely promising 'bendable' performance.
Hongyi Precision provides structural review, rapid prototyping, dynamic validation, and volume production support for FPC and FPCA solutions targeting humanoid robots, dexterous hands, joints, vision modules, and motor assemblies. Final specifications are subject to customer drawings, full-system operational conditions, and joint validation results.
Summary:The core of robot FPC selection lies in balancing motion compatibility, spatial fit, electrical performance, assembly feasibility, and long-term reliability. Clearly articulating real-world operating conditions upfront—before selecting materials or defining geometry—maximizes the likelihood that prototypes proceed directly to functional assembly validation.