
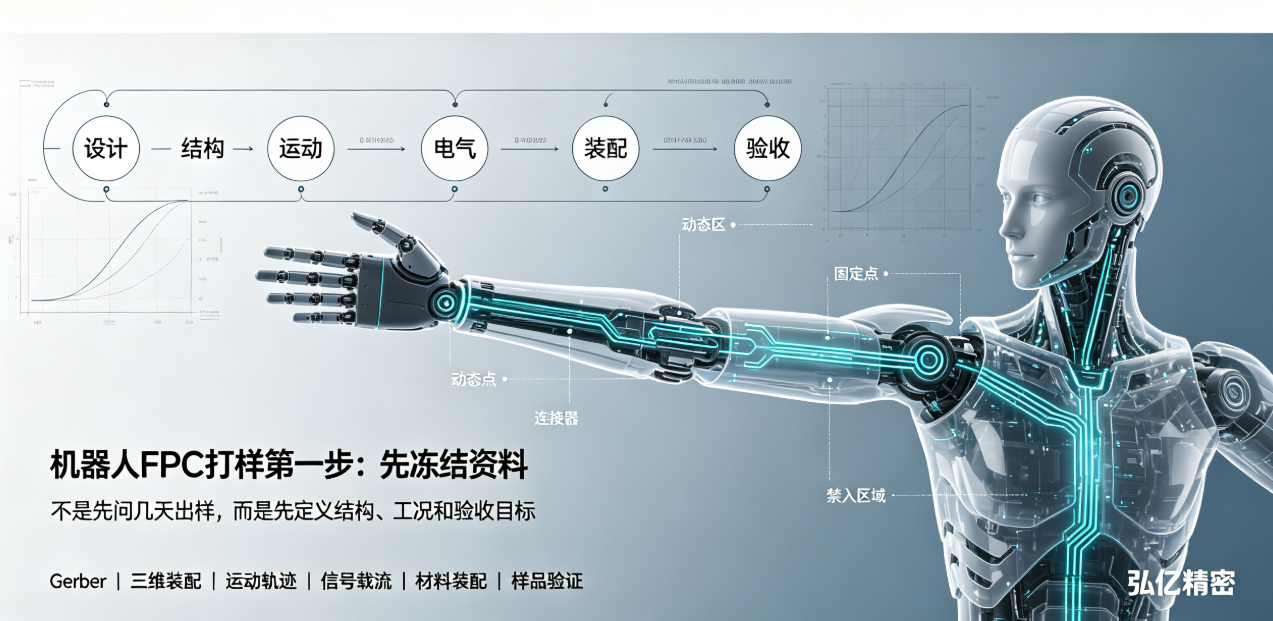
Robot FPC prototyping requires more than just Gerber files. Joints, dexterous hands, and vision modules also demand 3D structural data, extreme pose definitions, motion trajectories, connector specifications, signal requirements, and assembly instructions. This article outlines the pre-prototyping documentation checklist.
Many robot FPC prototyping projects experience delays—not due to factory capacity constraints, but because project documentation has not yet reached a review- or production-ready state.Internal robot interconnections typically involve spatial constraints, motion dynamics, signal integrity, current carrying, thermal management, and assembly considerations. Submitting only Gerber files leaves manufacturers unable to assess whether the FPC will be pinched or overstretched under extreme poses.
Before prototyping, robot FPC manufacturers recommend organizing documentation into six categories: design, structure, operating conditions, electrical specifications, assembly, and acceptance criteria—and maintaining consistent file versions across all categories. The closer the documentation reflects the actual integrated system, the higher the likelihood that first-run samples can proceed directly to assembly validation.
I. Design Documentation: Gerber Is Just the Starting Point
Baseline design documentation includes Gerber files, drill data, stack-up, layer count, copper thickness, trace width/spacing, impedance, coverlay openings, stiffener specifications, and outline tolerances. Any special surface finishes, shielding requirements, or restricted/forbidden materials must also be explicitly stated.
For robots undergoing iterative development, clearly indicate drawing revision numbers, release dates, and change summaries. When discrepancies arise among document versions, Hongyi Precision must pause scheduling and reconfirm specifications to prevent prototyping from incorrect data.
II. 3D Structural Data: Confirming Where the FPC Actually Fits
3D models or assembly schematics must annotate housings, bearings, motors, sensors, connectors, mounting points, clips, screws, and no-go zones. A free-state FPC fit does not guarantee clearance after full assembly.
Also provide assembly sequence and service/maintenance disassembly procedures. Some designs require connector insertion before bending; others necessitate routing the FPC through narrow gaps prior to fixation—sequence differences directly impact final geometry and localized stress distribution.
III. Operational Conditions: Clarifying Normal and Extreme Motions
For joint and finger applications, specify motion direction, angular range or linear stroke, minimum bend radius, frequency, cycle count, acceleration/deceleration profiles, and extreme poses. If torsion, lateral stretching, dwell time, or rebound occurs, these must also be documented.
Hongyi Precision uses this information to define dynamic zones, static zones, and fixed zones—and to evaluate trace orientation, stiffener boundaries, and connector support structures. Without motion trajectory data, only static form-fit assessment is possible; dynamic reliability design cannot be completed.
IV. Electrical & Signal Requirements: Quantity Alone Is Insufficient
Documentation must detail power, ground, sensing, encoder, tactile, high-speed signal, impedance, current-carrying capacity, voltage drop, and shielding requirements. When motor drive and low-level sensing signals coexist in proximity, return path design, crosstalk mitigation, and isolation strategies must also be addressed.
If current, frequency, or impedance parameters are finalized only after prototyping, stack-up, trace width/spacing, and interlayer design may require rework—leading to repeated prototyping cycles.
V. Materials & Assembly: Identifying Non-Negotiable Zones
Customers must explicitly define acceptable ranges for copper foil, polyimide (PI), coverlay, stiffeners, connectors, and surface finishes—including permissible substitution boundaries. Material requirements often differ across dynamic zones, connector terminations, pad areas, and mounting zones.
If SMT, connector, or sensor mounting is required, also supply BOMs, package footprints, component delivery formats, soldering conditions, fixturing requirements, and post-assembly test methods. Bare FPC and FPCA prototyping timelines and acceptance criteria must not be conflated.
VI. Acceptance Criteria: Defining What the Sample Must Demonstrate
Is the sample intended to verify form, continuity, assembly fit, or dynamic motion—or to advance into reliability testing and small-batch evaluation? Different objectives dictate distinct sample quantities, test protocols, and reporting requirements.
We recommend specifying dimensional tolerances, electrical performance, visual inspection criteria, connector functionality, bend endurance, temperature/vibration resistance, lifetime targets, sample size, and failure criteria within the prototyping documentation. This enables manufacturers to deploy appropriate tooling, inspection methods, and sample counts.
Robot FPC Prototyping Documentation Checklist
Gerber files, stack-up, material specs, stiffener details, and outline tolerances;
3D model, mounting points, connector locations, and no-go zones;
Motion direction, stroke/range, bend radius, frequency, and lifetime targets;
Signal types, power rails, current ratings, impedance, grounding, and shielding requirements;
BOM, assembly sequence, soldering parameters, fixturing, and test methodology;
Sample quantity, verification items, report fields, and pass/fail criteria.
For routing in confined spaces, refer toKey Routing Considerations for Robot FPC in Joints and Dexterous Hands; for system-level selection between FPC and harnesses, seeFPC vs. Traditional Harness Selection Analysis for Robots.
Hongyi Precision provides structural evaluation, prototyping, dynamic validation, and volume production support for FPC and FPCA used in humanoid robots, dexterous hands, joints, vision modules, and motor modules. Specific material selections, stack-ups, structural configurations, and lead times require confirmation based on complete project documentation.
Summary:The first step in robot FPC prototyping is not asking 'How many days for samples?'—but rather clearly communicating 3D structure, motion trajectory, signal requirements, and acceptance goals upfront. Complete documentation empowers manufacturers like Hongyi Precision to resolve real issues during the first prototype iteration.